Probe-to-Grasp
IROS 2026 · 2026
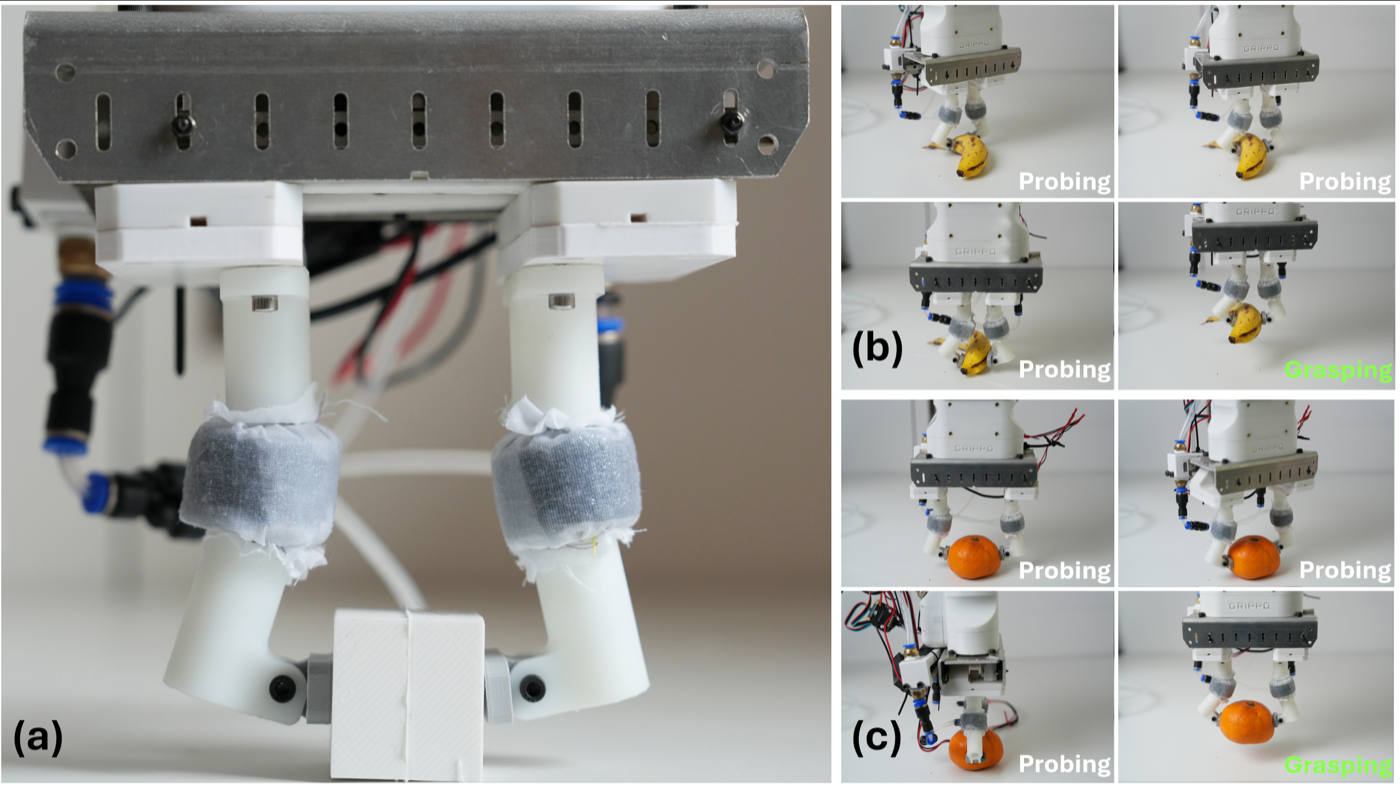
Grasping deformable objects with varying stiffness remains a significant challenge in robotics. This project presents a probe-to-grasp manipulation framework for estimating relative object stiffness using a passive soft-rigid two-finger hybrid gripper equipped with self-sensing pneumatic variable-stiffness joints.
By measuring internal pressure during contact, the system estimates interaction force and uses a practical probing strategy to infer relative object stiffness before grasping. The approach is validated through stiffness characterization experiments and real-world fruit grasping scenarios with spatially varying stiffness.
Video
Publication
N. D. Tran, Y. Fan, F. Dai, K. Nguyen, A. Nguyen, H. H. Ly, T. D. Ta, and S. Chiba, “Probe-to-Grasp Manipulation Using Self-Sensing Pneumatic Variable-Stiffness Joints,” IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026. arXiv PDF DOI.