MobiDock
IROS 2026 · 2026
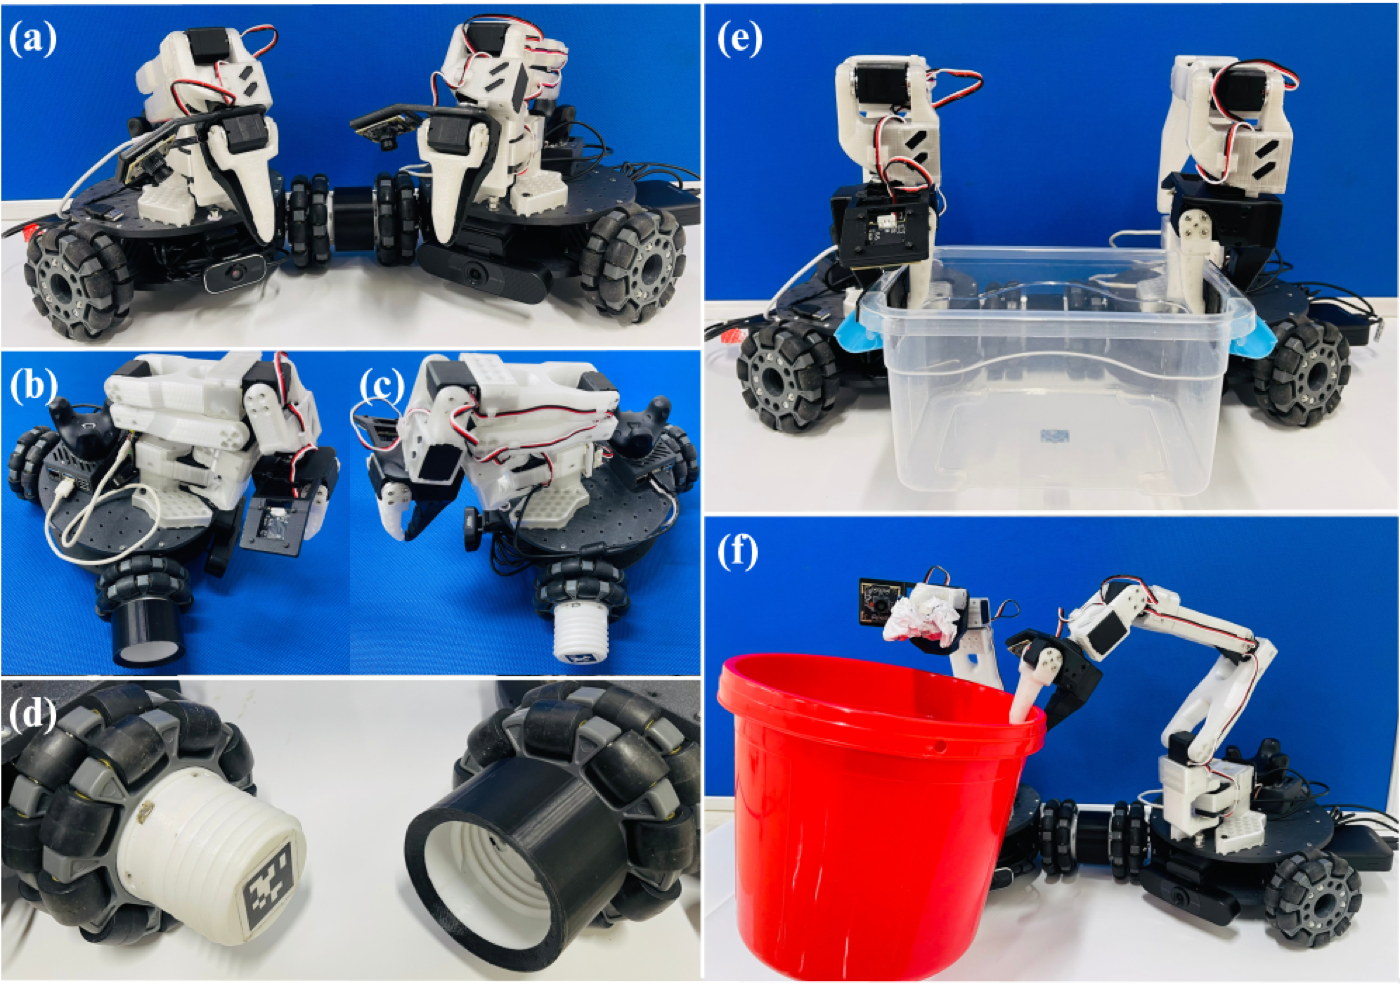
MobiDock presents a modular self-reconfigurable bimanual mobile manipulator built through robotic docking between two independent mobile robots.
The system combines autonomous vision-based docking with a screw-lock mechanism so the two robots can form a unified platform with improved stability and task efficiency for coordinated manipulation.
Paper: arXiv
Publication
X.-T. Nguyen, K. N. Nguyen, N. D. Tran, T. T. Mac, A. Nguyen, H. H. Ly, and T. D. Ta, “MobiDock: Design and Control of A Modular Self Reconfigurable Bimanual Mobile Manipulator via Robotic Docking,” IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026. arXiv PDF DOI.