GCA-Bench
IROS 2026 · 2026
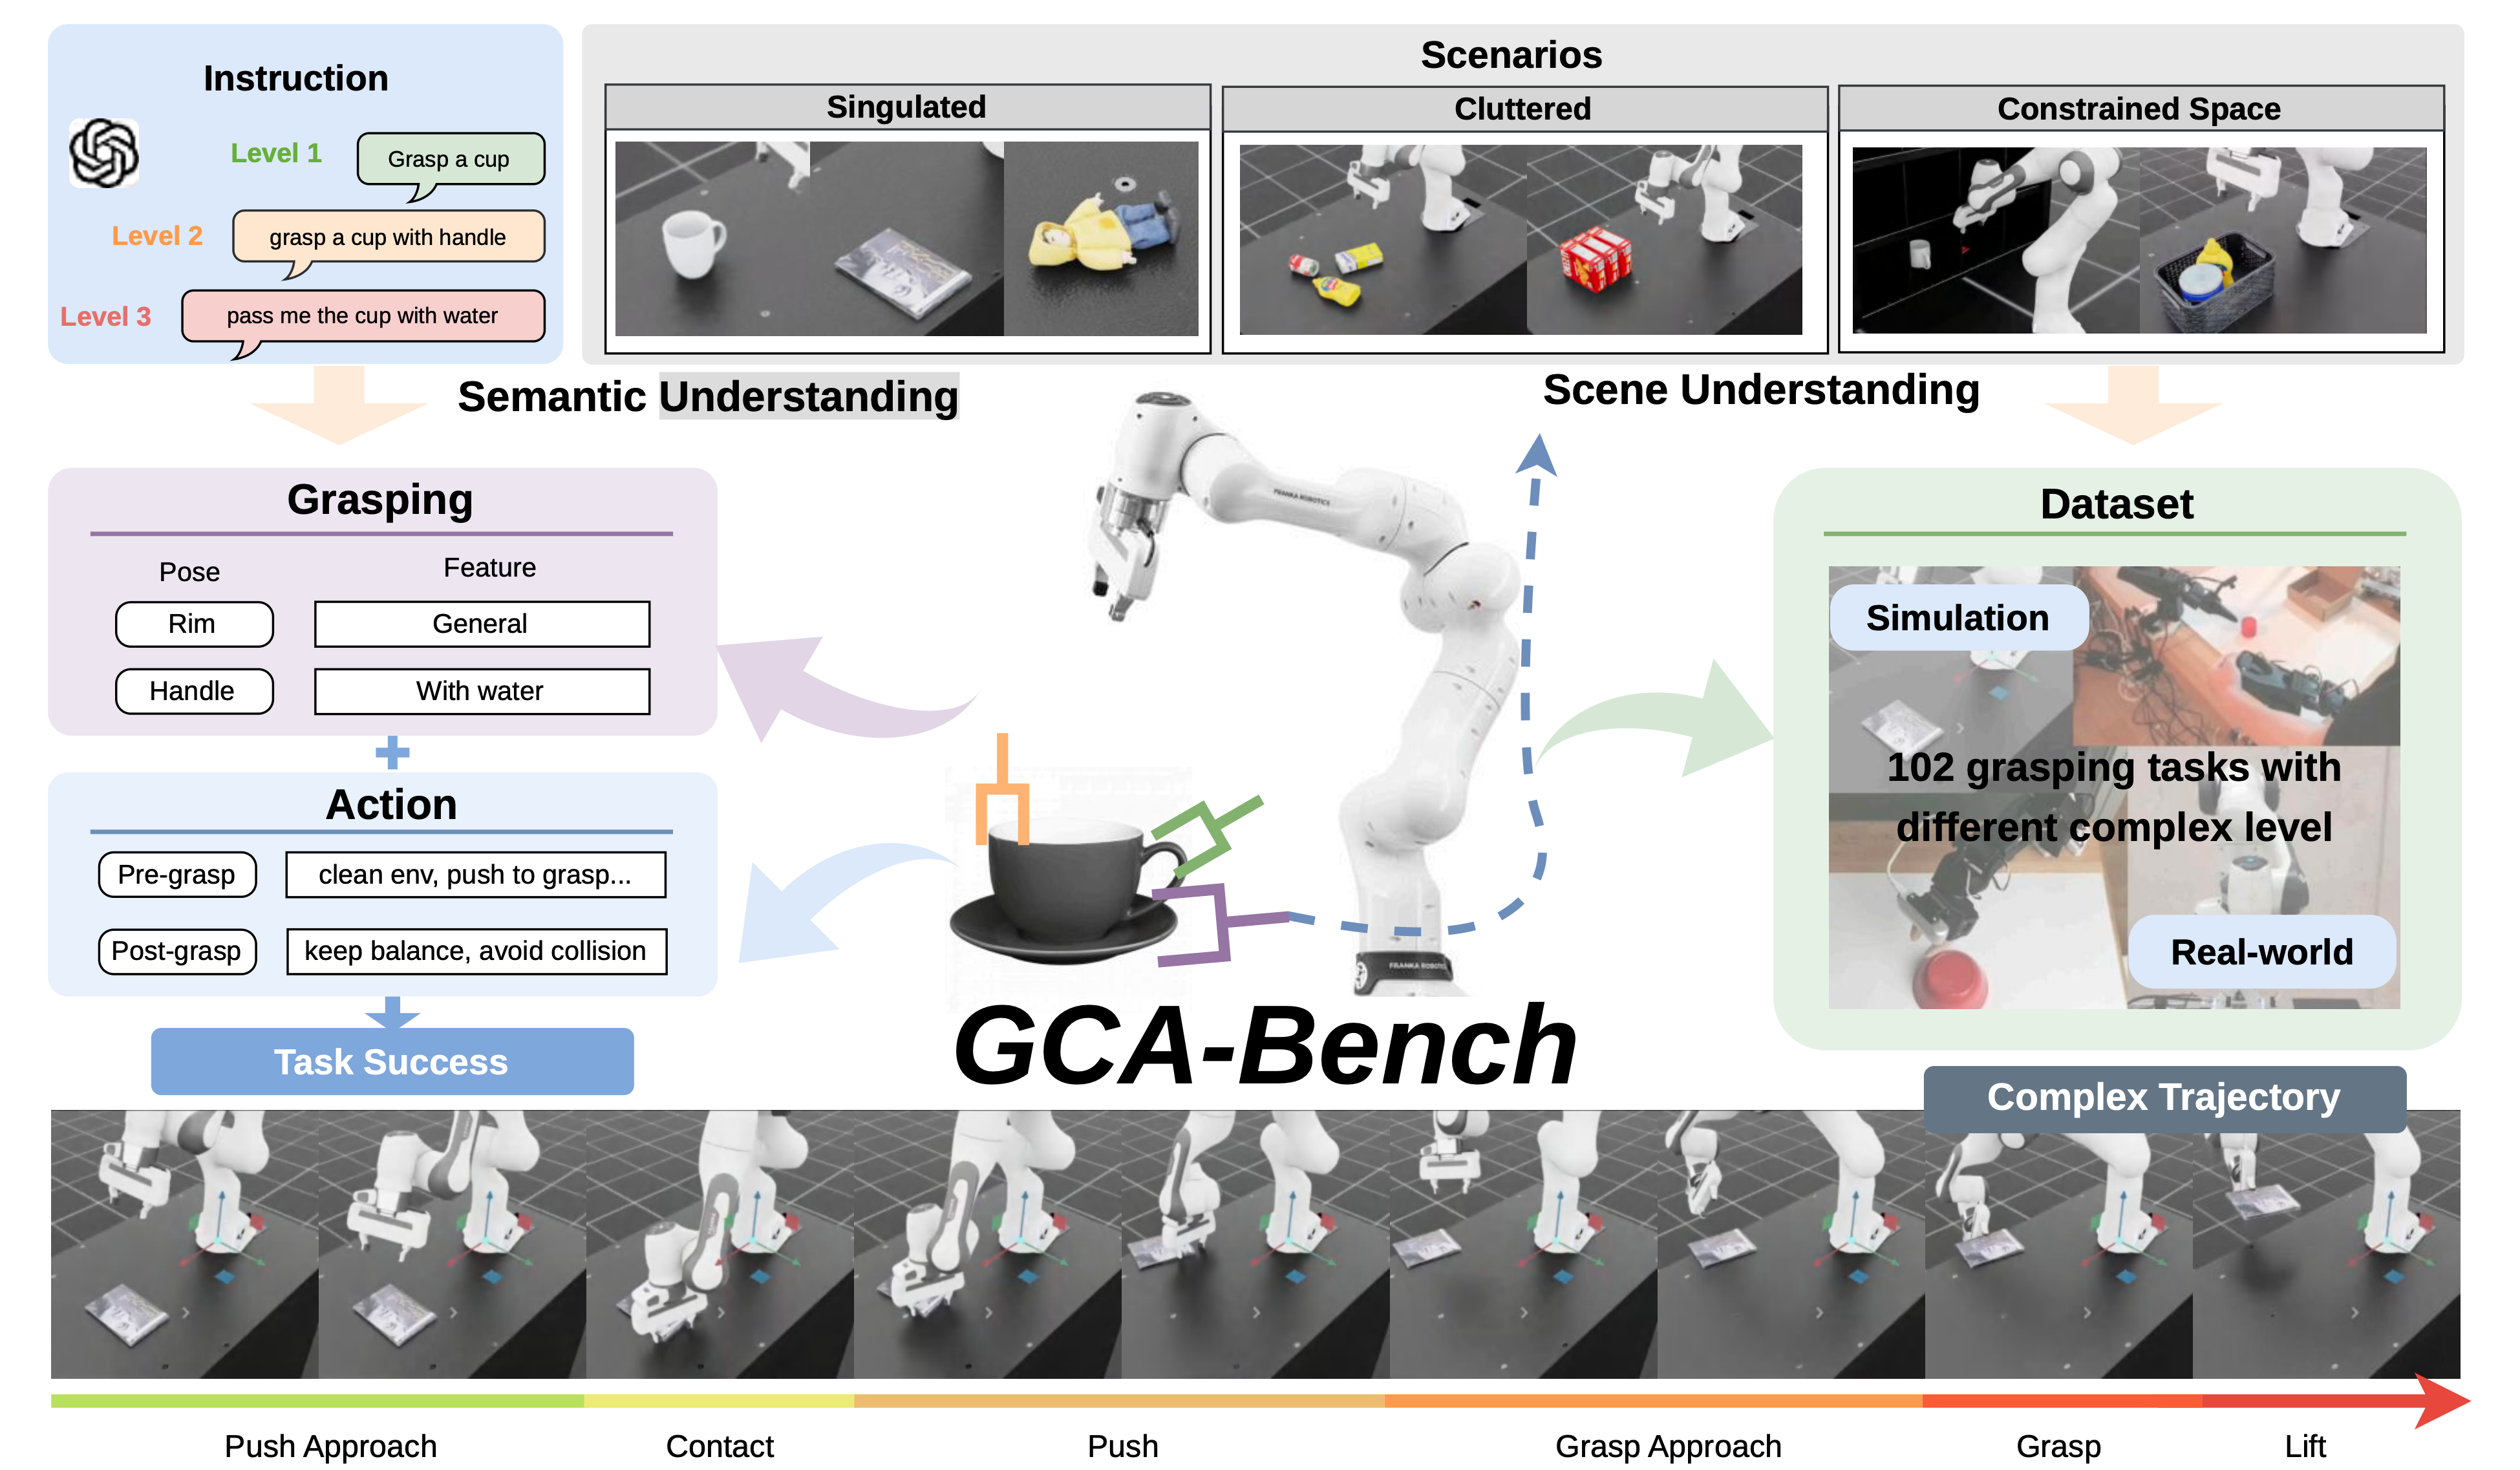
GCA-Bench explores robotic grasping beyond grasp pose detection by benchmarking the full pipeline from semantic reasoning and scene understanding to trajectory planning and physical execution.
The benchmark targets cluttered, constrained, and language-conditioned grasping scenarios, and combines both simulation and real-world datasets for evaluating modern robotic manipulation systems.
Publication
H. Zhang, K. Nguyen, C. Munasinghe, B. Hela, T. Li, Z. Luo, H. Nguyen, H. W. van de Venn, Y. Zheng, R. Prakash, T. D. Ta, A. Nguyen, and B. Huang, “Beyond Visual Grasping: Benchmarking Complex Robotic Grasping from Detection to Execution,” IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026. arXiv forthcoming. DOI forthcoming.